Build a Flock, Not a Crowd
Agents that each keep their own copy of the same know-how drift apart. Skills give that knowledge one home, loaded only when a task needs it, so the whole fleet improves together.
Software engineer at Dust, building AI agents and the product around them.
Agents that each keep their own copy of the same know-how drift apart. Skills give that knowledge one home, loaded only when a task needs it, so the whole fleet improves together.
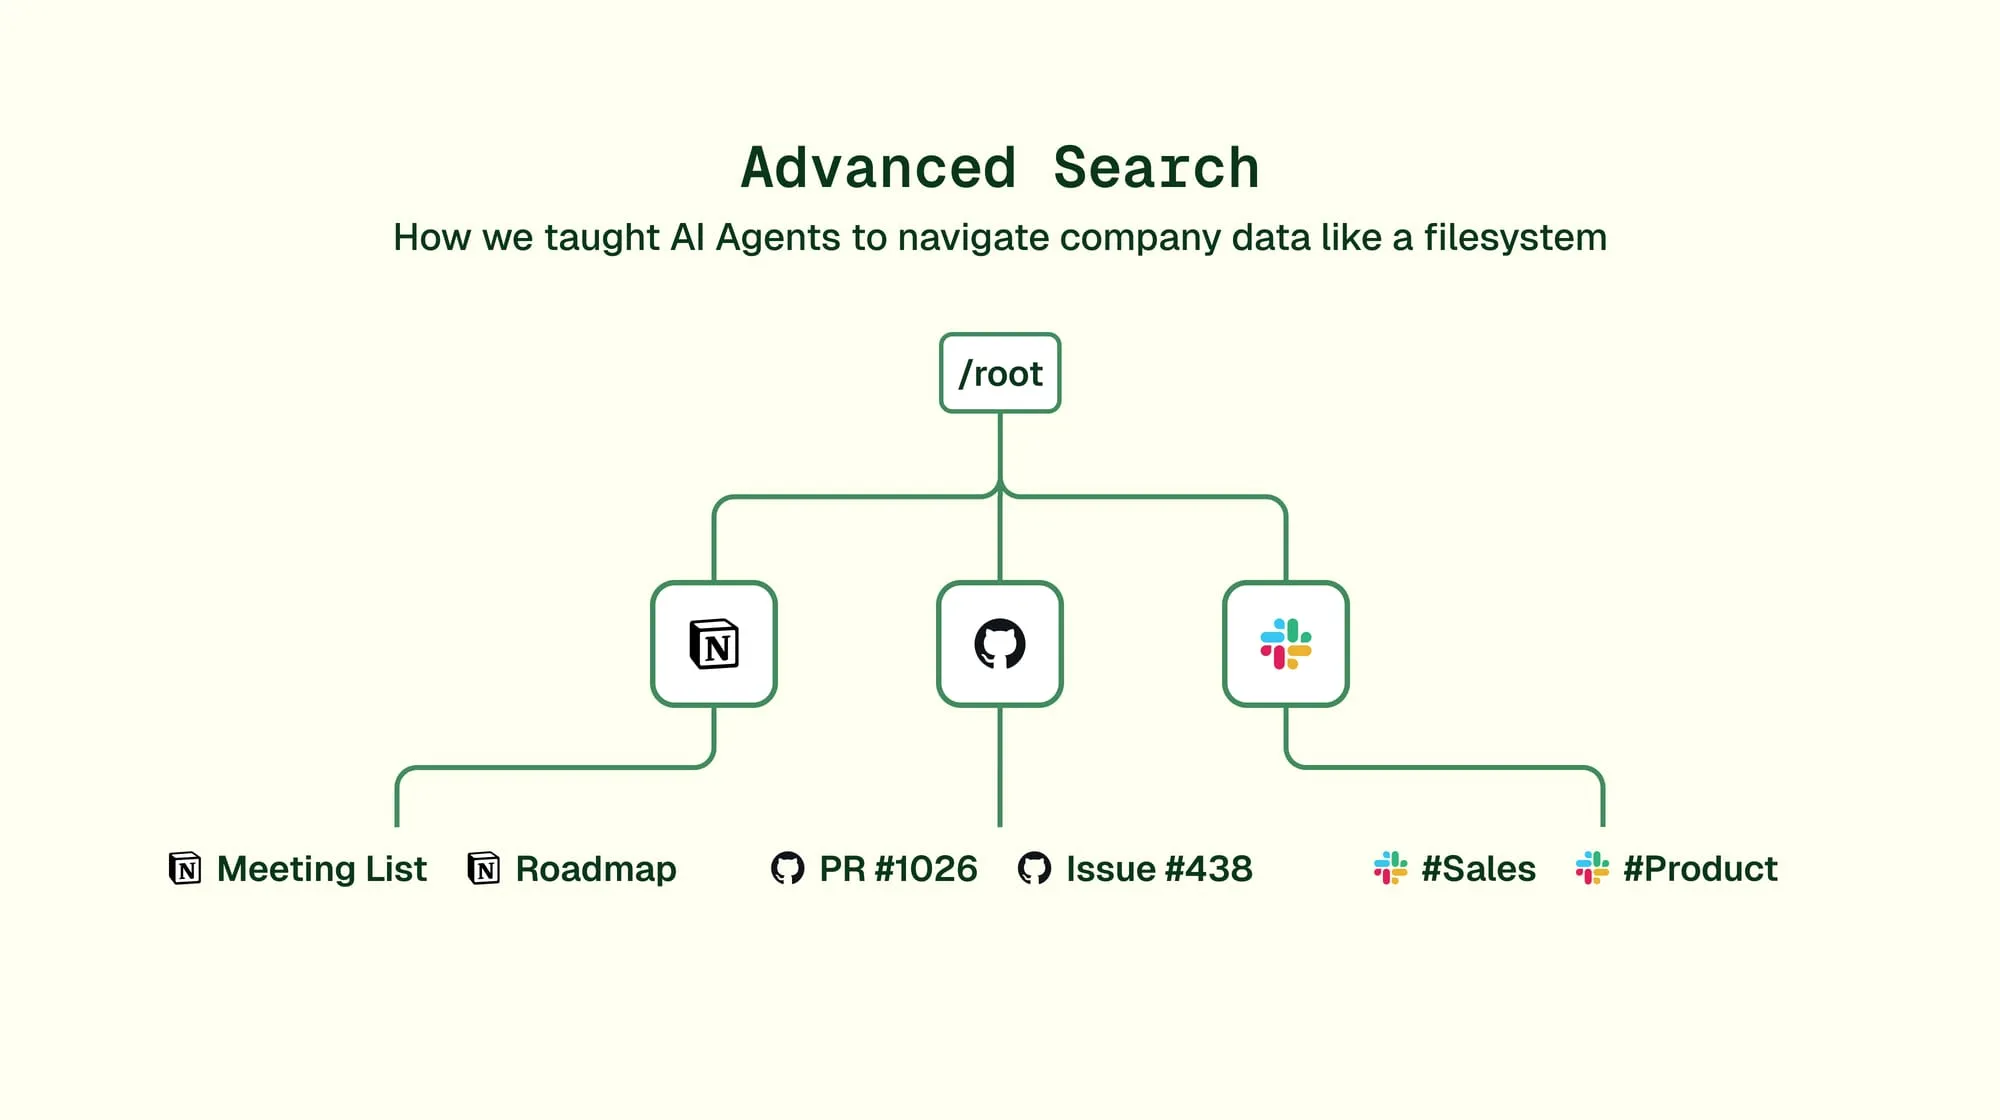
Our agents kept inventing file paths, so we gave them a filesystem: Notion, Slack, GitHub, and Drive mapped onto one tree they can list, find, read, and search.
3D computer vision at Exwayz, applied mathematics at ENS Paris-Saclay.
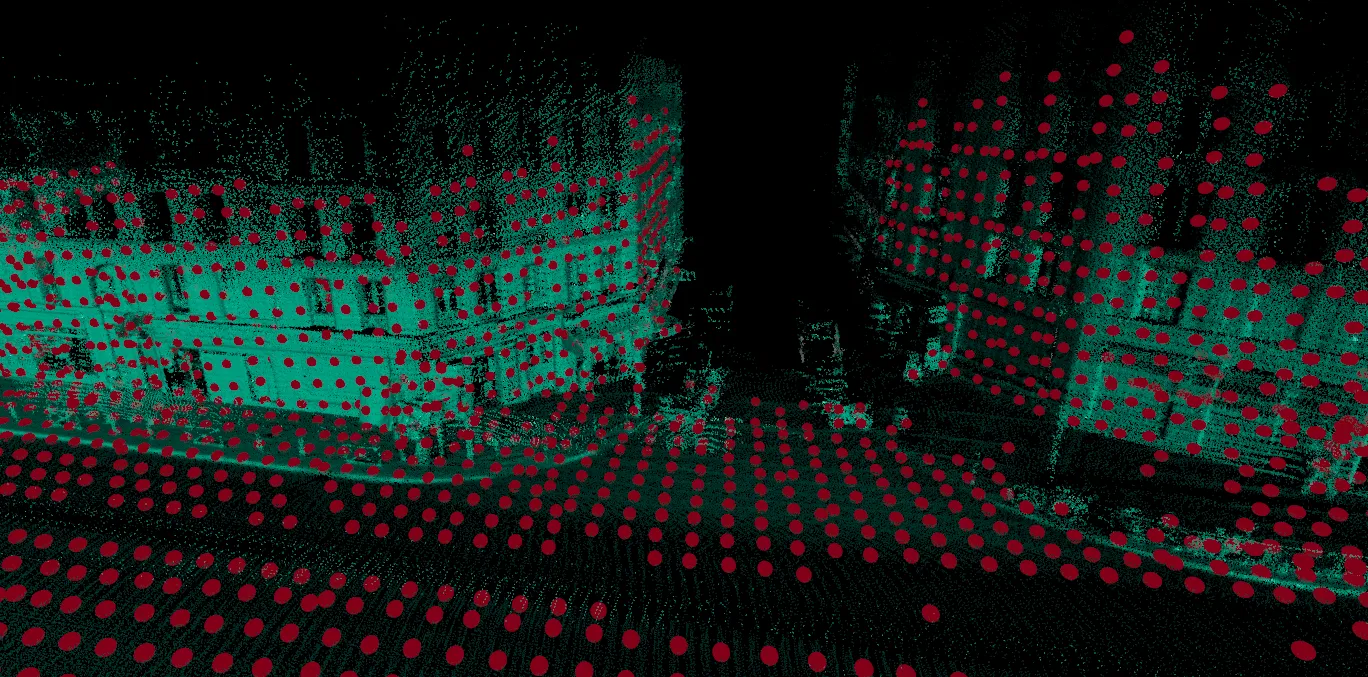
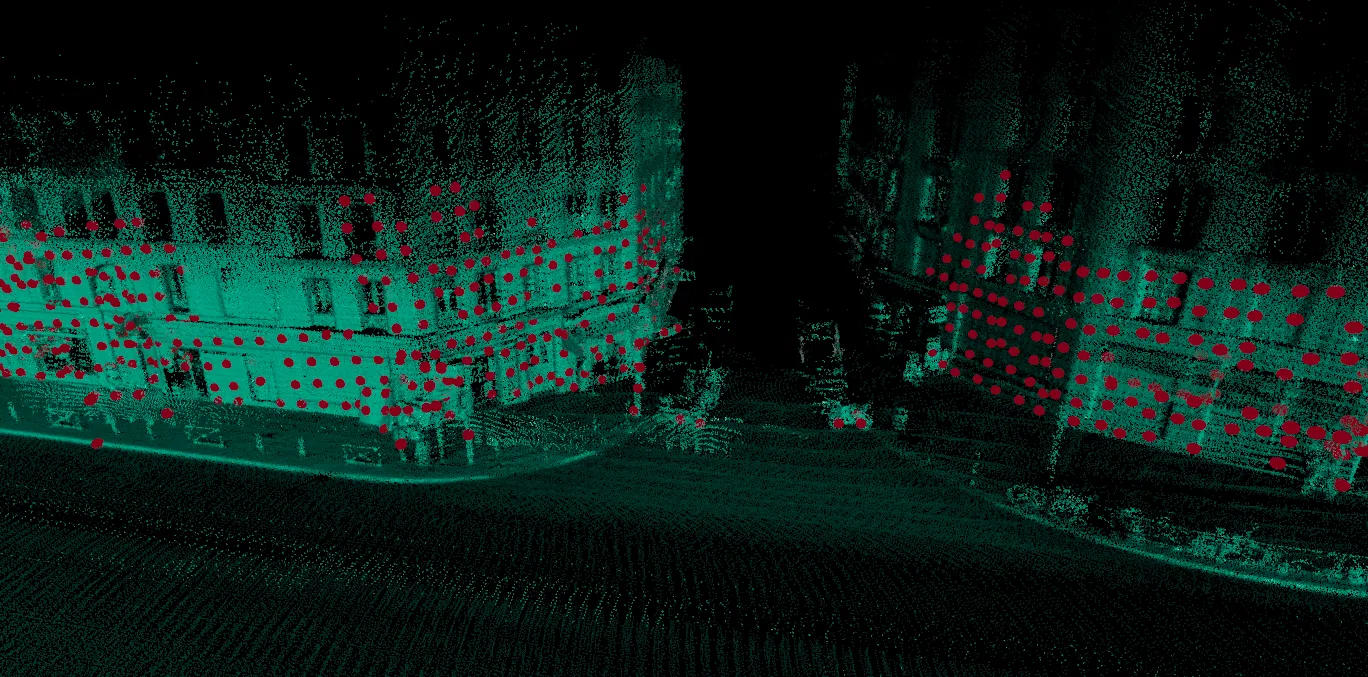
Keeps only the keypoints worth matching: edges and corners, scored by the entropy H of nearby normals.
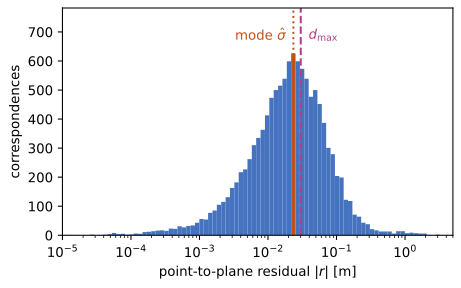
Sets the ICP outlier cutoff from the mode of point-to-plane log-residuals, which follows the sensor noise and ignores the outliers.
Multiscale covariance eigenfeatures, then region growing to smooth labels per object: 75.1% mean IoU.